Day 2: Mecanum Wheels
This is day 2, and I’ll be explaining why I will be using mecanum wheels for my project. Parkit is a robot that is supposed to not just make the customers’ lives easier by helping you and everyone else park your cars but also be able to park your car in a more efficient way. We do not want your cars going forward, coming back, then going forward and coming back again till you find the exact orientation of your car with which it can reverse onto the parking spot.
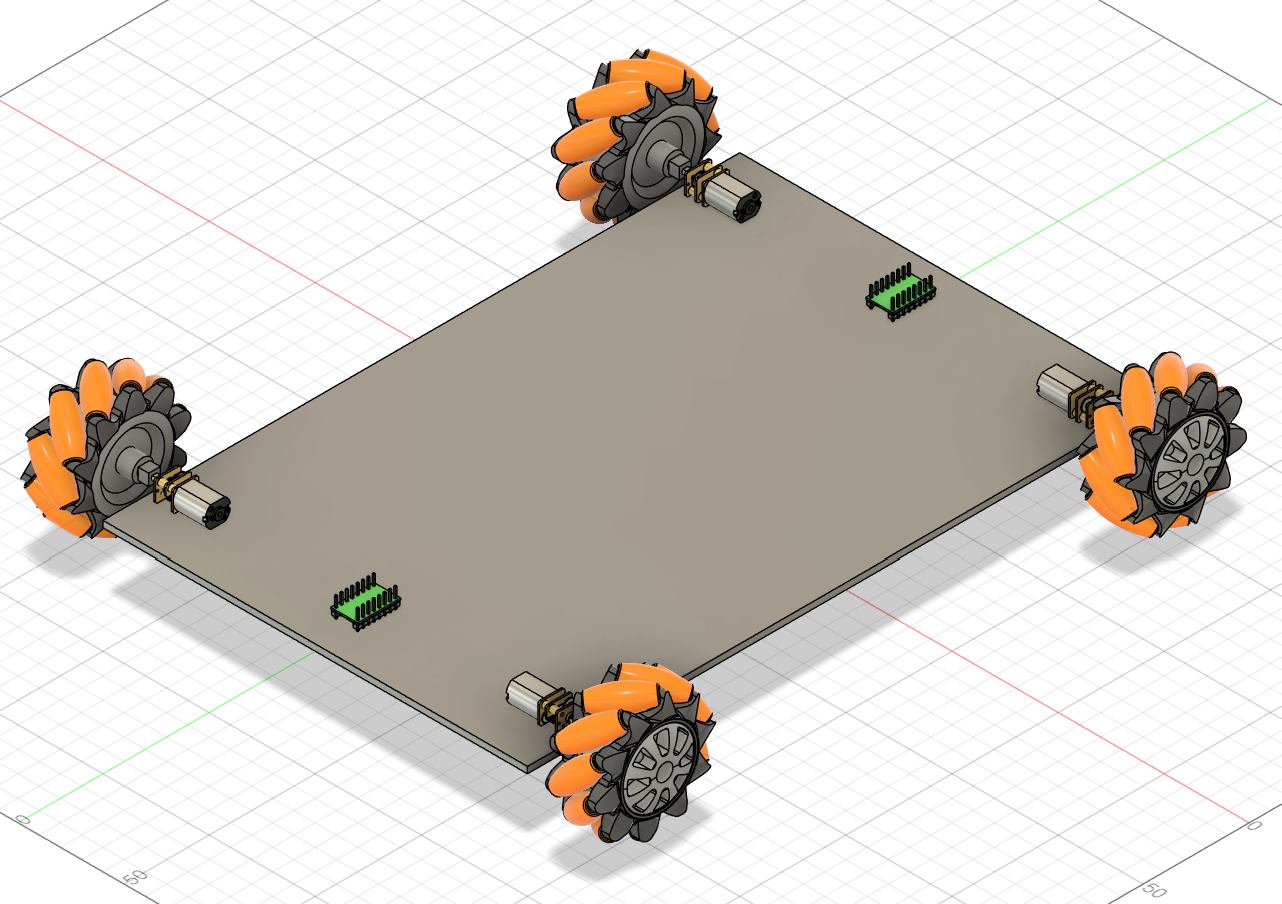
With mecanum wheels, you can move front, back, left, right and rotate clockwise or anti-clockwise, making parking a lot faster. With the right kind of programming, this robot should be able to park your tiny vehicle accurately and efficiently.
For the DC motors that drive my robot, I had 2 options in mind: a simple TT motor or an N20 geared motor. It was a pretty simple choice; this robot will have the job of taking the load of an RC car, hence there is a requirement for high torque, so I have decided to go with the N20 geared motors.
I will be using the DRV8833 motor driver, which can control 2 DC motors at a time. With a 4-wheel driving robot, I will need 2 DRV8833 motor drivers, 4 mecanum wheels and 4 N20 geared motors.
Follow along as I choose my microcontroller, my sensors, and my lifting mechanism, and I will show you my progress on how my design slowly evolves as the days pass by. That’s a wrap for day 2.